UCLA · 5-DOF Cake Icing Robotic System
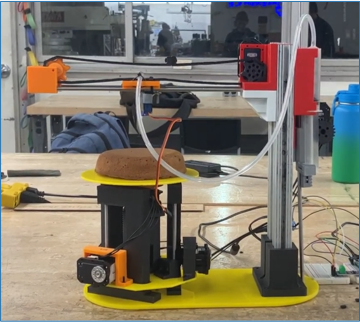
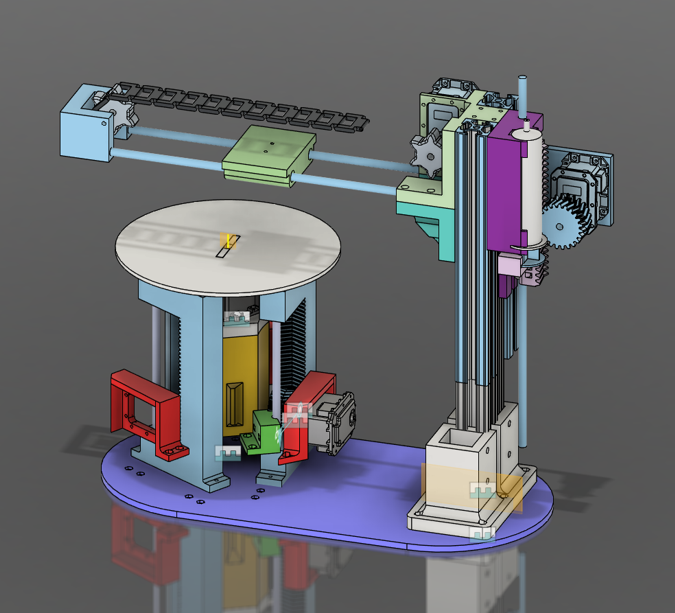
Designed, fabricated, and validated a 5-DOF robotic manipulator for automated cake icing, developed as part of RoMeLa at UCLA (Fall 2025). The system achieves full coverage of cylindrical cake surfaces — both top and sides — through coordinated translational and rotational motion without requiring a full X–Y gantry, reducing actuator count and mechanical complexity.
The robot architecture distributes five degrees of freedom across three subsystems: a base platform providing Z-axis lift (rack-and-pinion driven by three synchronized motors with steel guide rods and linear bearings) and cake rotation (direct-drive motor beneath a laser-cut turntable); a syringe extrusion mechanism converting rotary motor output to linear plunger displacement via a rack-and-pinion with double-angled tooth profile for reduced backlash; and a belt-driven X-axis carriage with an articulating end-effector for adjustable nozzle orientation. All structural components were custom-designed in CAD and 3D-printed.
Forward and inverse kinematics were derived using Denavit–Hartenberg parameters, with inverse kinematics formulated in both Cartesian and cylindrical coordinates (using atan2 for singularity-free computation). Velocity-level control was implemented by differentiating the inverse kinematic equations to yield joint-rate commands from desired end-effector trajectories. Workspace analysis confirmed a cylindrical reachable workspace with no dexterous workspace due to the 90° nozzle rotation limit. Task simulations demonstrated polar spiral icing on the top surface, wave patterns on the sides, and Cartesian letter-writing — outperforming commercial solutions such as the Cakewalk 3D, which is limited to flat-surface icing.