Work
Selected
projects
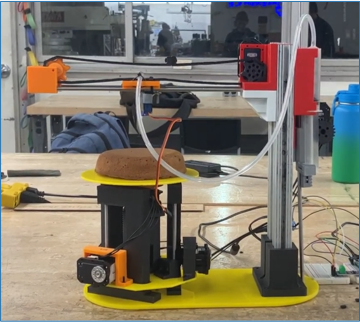
UCLA · RoMeLa · Fall 2025
UCLA · 5-DOF Cake Icing Robotic System
Designed and fabricated a 5-DOF robotic manipulator with Cartesian motion, rotation, and syringe-based extrusion using custom 3D-p...
RoboticsKinematics3D Printing
View project →
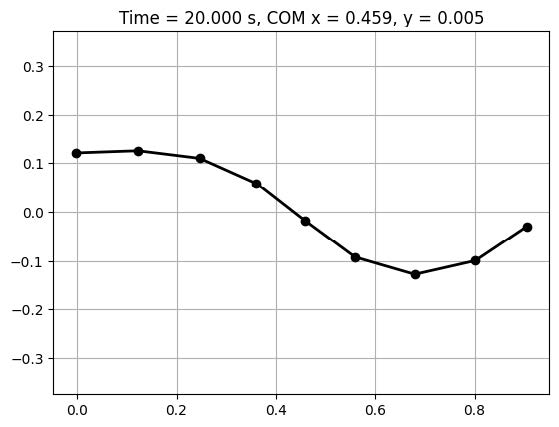
UCLA · Fall 2025
UCLA · Bio-Inspired Elastic Tail Dynamics
Modeled a curvature-driven elastic tail as a discrete elastic rod in low-Re fluids. 192-case parameter sweep showed near-linear propulsion scaling with amplitude and frequency; glycerol yields 1000× greater displacement than water.
DERMATLABBio-Inspired Robotics
View project →
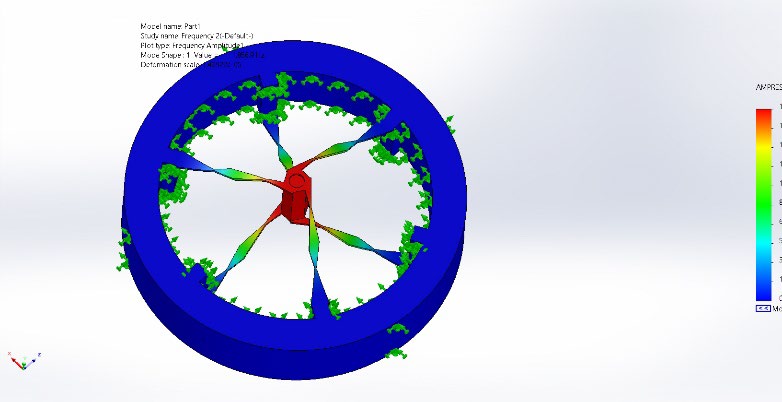
UCLA · Winter 2025
UCLA · Translational 1-DOF Compliant Micro-Mirror
Designed and analyzed a flexure-based micro-mirror using FACT topology synthesis. FEA-validated natural frequencies of 11,667 rad/s and 146,869 rad/s satisfy order-of-magnitude separation requirement.
Compliant MechanismsMEMSFEA
View project →
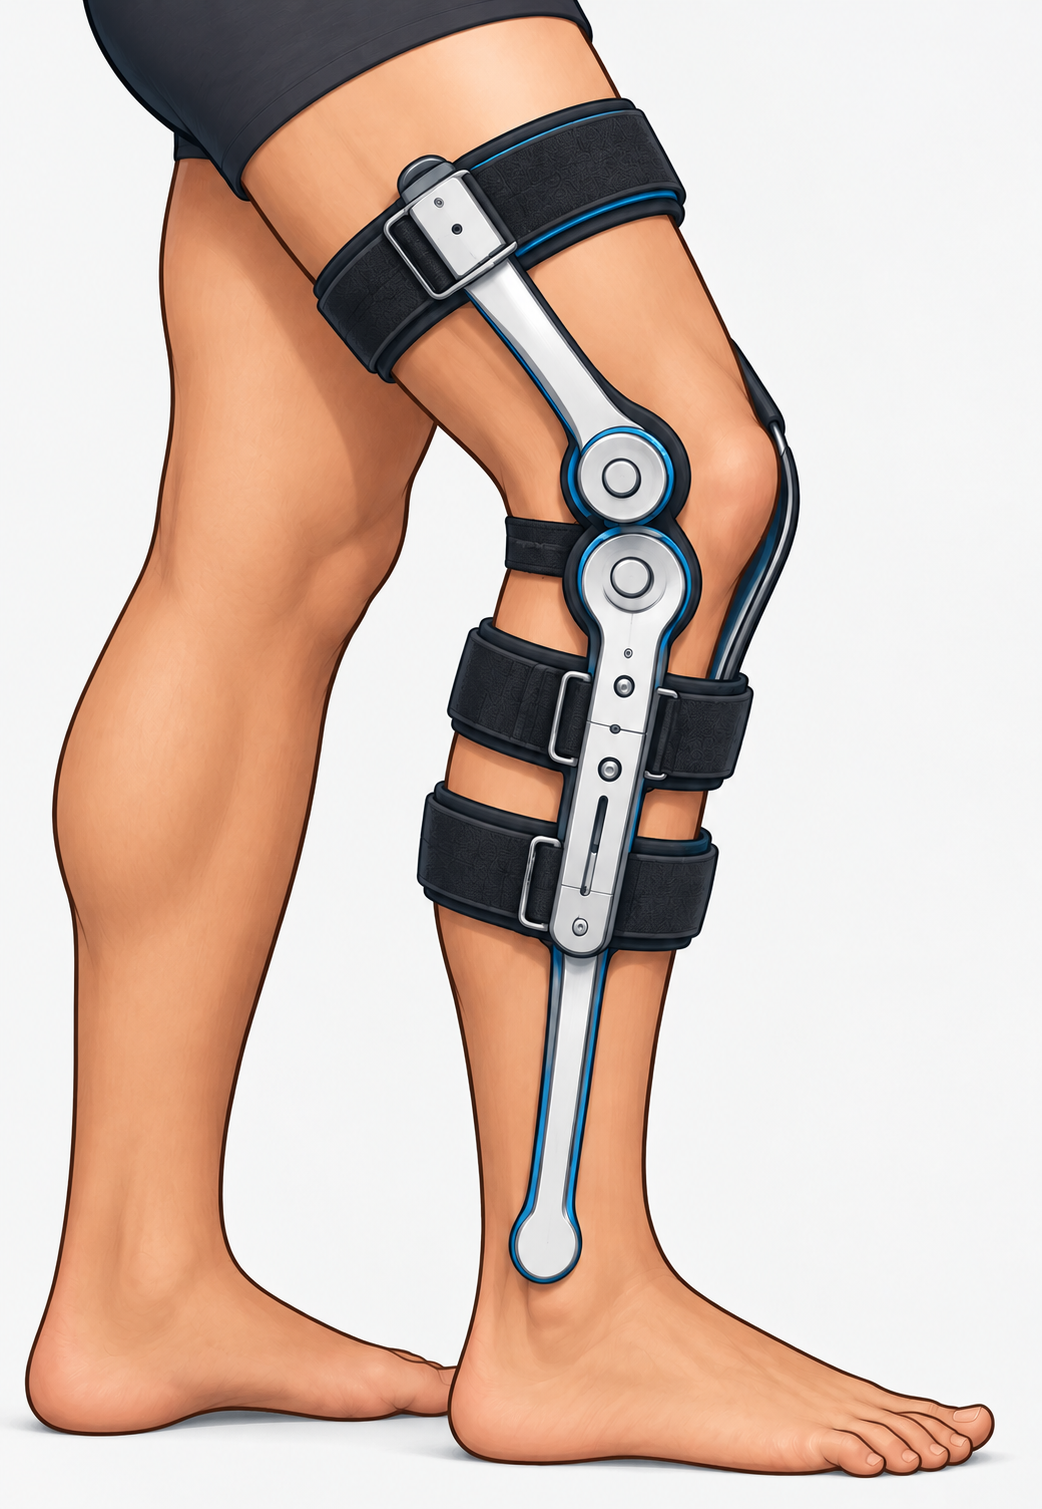
UCLA · Fall 2024
UCLA · Knee Exoskeleton for Quadriceps Myopathy
Designed a motor-driven knee exoskeleton to assist gait in patients with 35–70% quadricep force loss. Optimized torque profile, motor selection, and transmission ratio using OpenSim CMC and MATLAB.
BionicsOpenSimExoskeleton
View project →
UCLA · GuptaLab · Fall 2024–Present
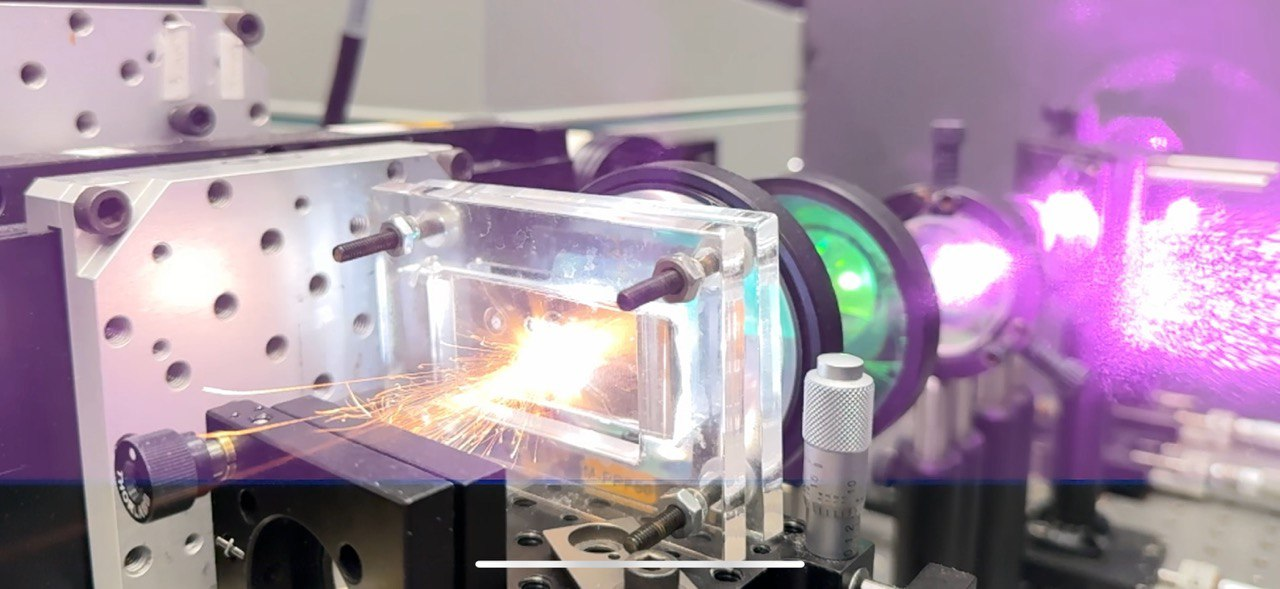
UCLA · Laser-Driven Micro-Impact Platform
Table-top platform generating impact velocities up to 4 km/s and ~10⁸ s⁻¹ strain rates. Engineered multilayer thin-film coatings a...
Solid MechanicsOpticsInstrumentation
View project →
UCSD · Winter 2024
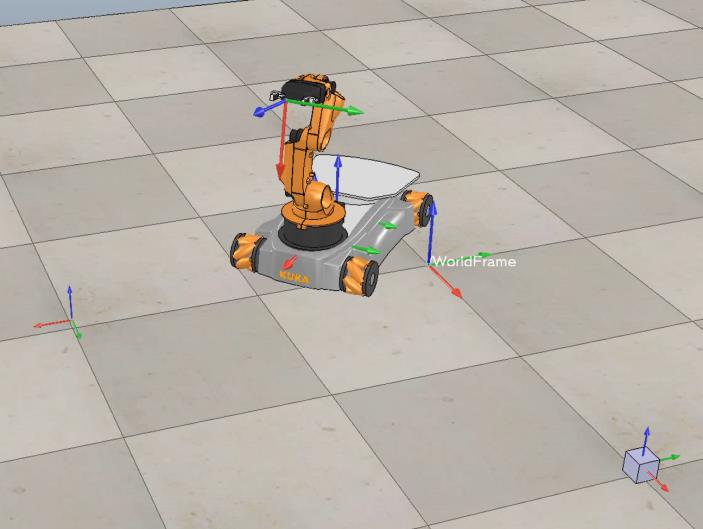
UCSD · KUKA YouBot Mobile Manipulation
Full motion planning and Feedforward+PI control pipeline for the KUKA YouBot in MATLAB and CoppeliaSim. Three scenarios evaluated including overshoot, best-case, and custom task configurations.
Potential FieldsDijkstraMATLAB
View project →
UCSD · Winter 2024
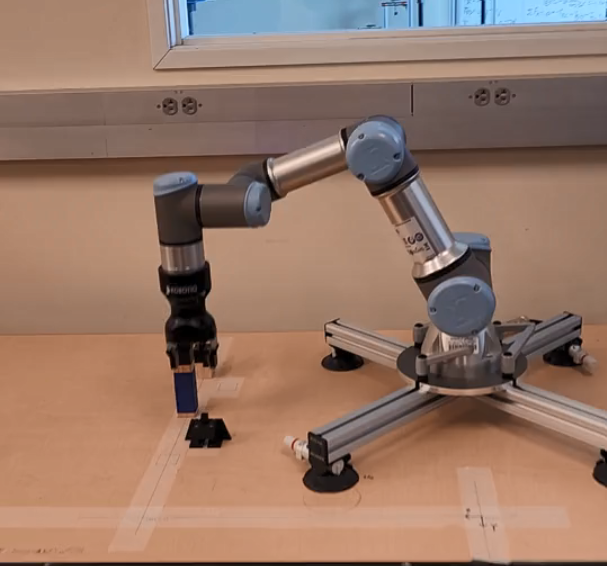
UCSD · UR3e Robot Laboratory Series
Three-lab series covering robot programming (Tower of Hanoi), forward kinematics (product-of-exponentials), and numerical inverse kinematics (Newton–Raphson) on the Universal Robots UR3e with Robotiq gripper.
UR3eKinematicsMATLAB
View project →
UCSD · Bioinspired Robotics Lab · Winter 2024
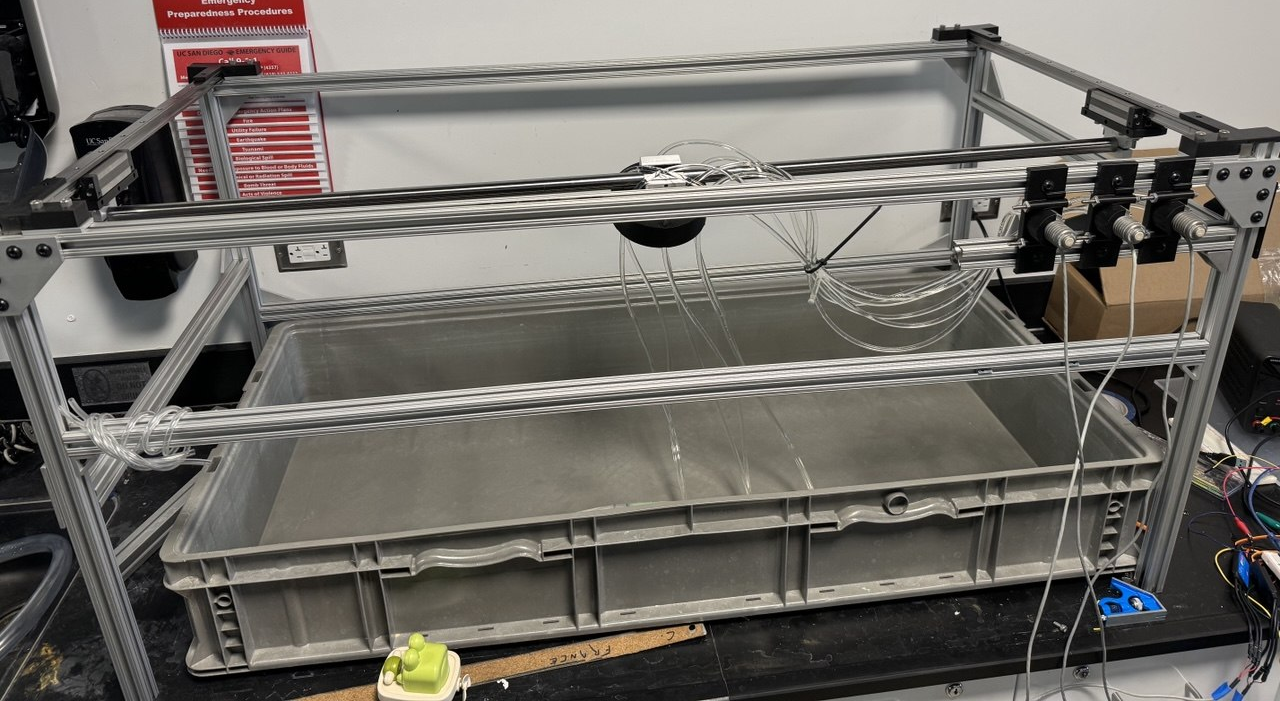
UCSD · 2-DOF Gantry for Eel Robot
Designed a 2-DOF gantry enabling smooth planar motion for a bio-inspired eel robot during locomotion experiments. Attenuated >9...
Bio-Inspired RoboticsMechanism Design
View project →
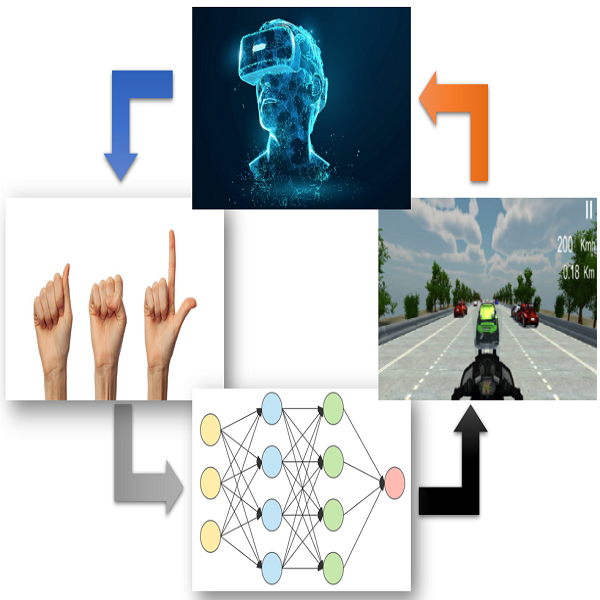
SUT · Robotics System Lab · 2022–2023
SUT · Teaching Iranian Sign Language via VR
Built real-time deep learning models for sign language gesture recognition integrated into a Unity VR environment. The AI-driven e...
Deep LearningVR / UnityIEEE Published
View project →
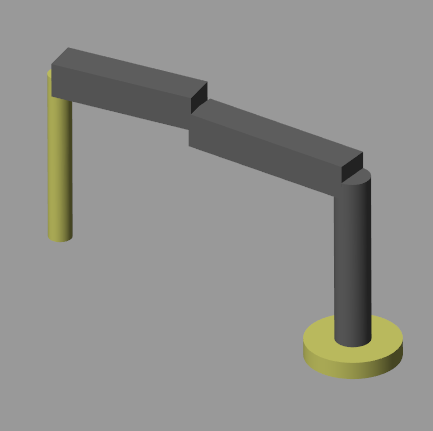
SUT · Spring 2022
SUT · GA-Optimized PID Control of SCARA Robot
Tuned PID controllers for a SCARA robot using a Genetic Algorithm in MATLAB, achieving ~20% improvement in tracking accuracy and r...
Control SystemsOptimizationMATLAB
View project →
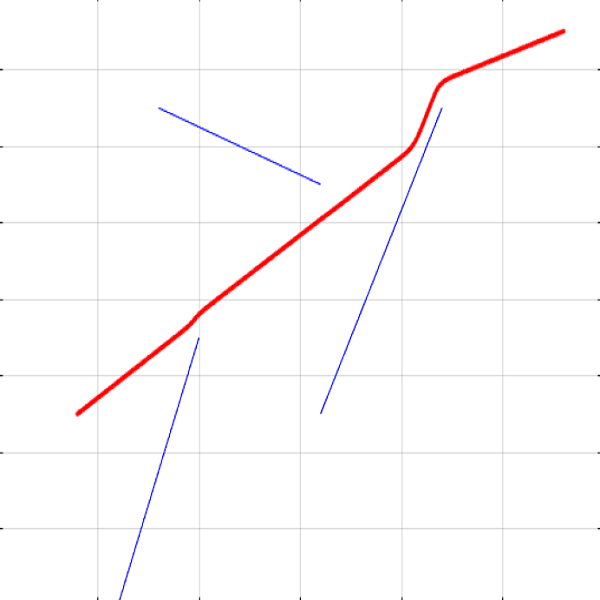
SUT · Winter 2022
SUT · Robot Path Planning: Potential Fields & Shortest Path
Implemented time-optimal trajectory planning in CoppeliaSim under velocity and acceleration constraints, completing pick-and-place...
Motion PlanningCoppeliaSim
View project →
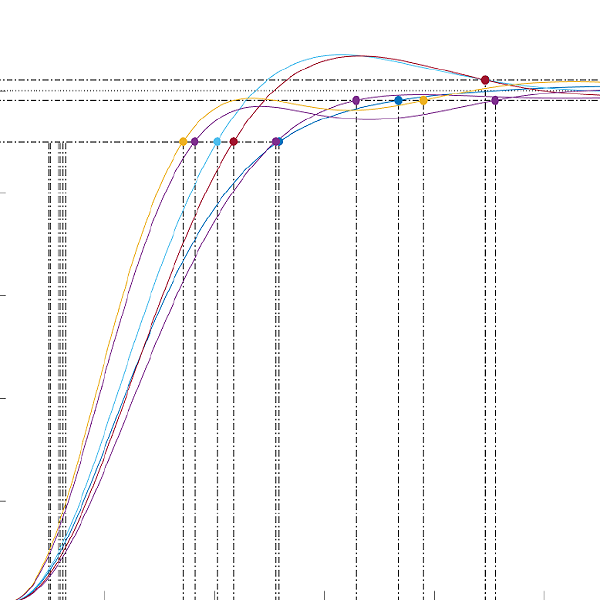
SUT · Winter 2022
SUT · Automatic Control of Ball & Beam System
Designed and implemented automatic control systems for a ball-and-beam plant using root locus, frequency response, and state-space...
Control DesignMATLAB / Simulink
View project →
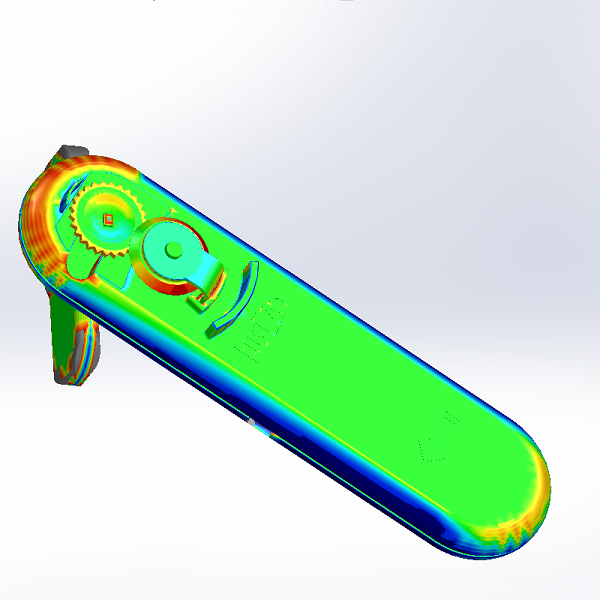
SUT · Fall 2021
SUT · Reverse Engineering of a Can Opener
Complete reverse engineering and redesign including technical drawings, blueprints, tolerances, and full manufacturing documentati...
CADReverse EngineeringGD&T
View project →
SUT · Spring 2021
SUT · Multi-Functional Sports Step Platform
Full mechanical design and development of a sports training platform including structural FEA analysis, component selection, CAD m...
Mechanical DesignFEAFabrication
View project →