UCSD · 2-DOF Gantry for Bio-Inspired Eel Robot
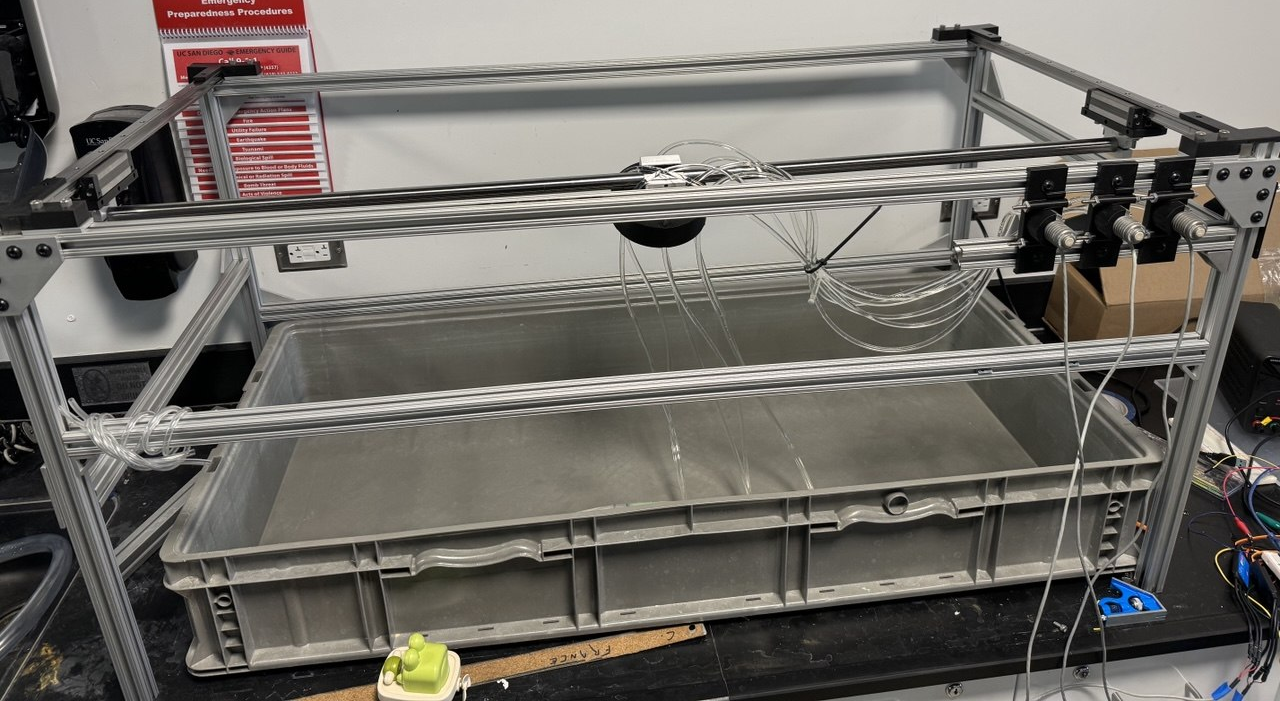
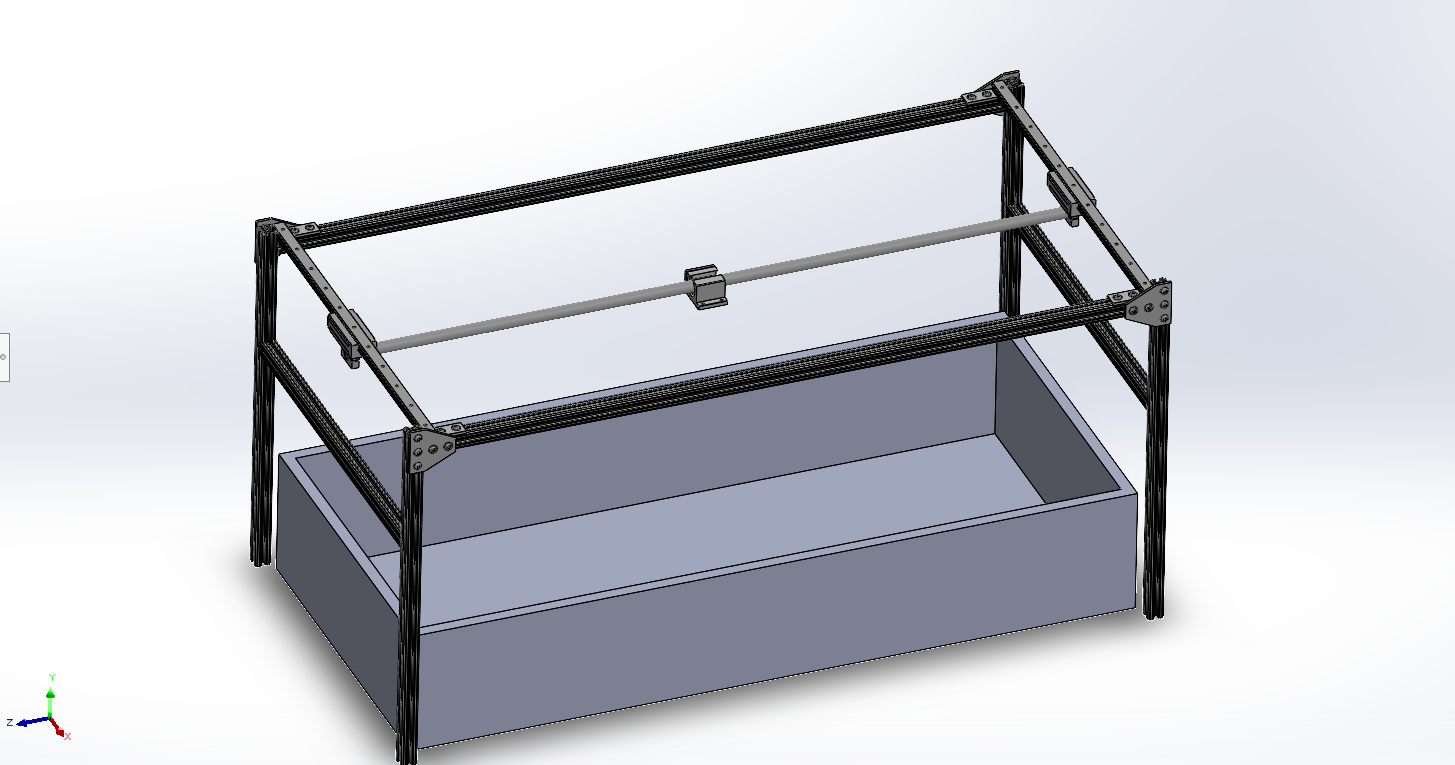
Designed and fabricated a 2-DOF planar gantry system for the locomotion testing of a bio-inspired eel robot at the Bioinspired Robotics and Design Lab, UC San Diego. The gantry enables unrestricted smooth planar motion of the robot during undulatory locomotion experiments, decoupling the robot's self-propulsion dynamics from ground-contact forces and boundary constraints that would otherwise contaminate experimental measurements.
The mechanism was designed to minimize friction and inertia in the gantry's passive DOFs, ensuring that the measured forces and velocities reflect the robot's intrinsic locomotion performance rather than gantry-induced artifacts. Structural analysis confirmed that the system attenuates more than 90% of external vibration transmission from the environment to the robot, a critical requirement for accurate force and motion sensing during low-speed bio-inspired swimming experiments.
The design process encompassed kinematic layout selection, bearing and rail component specification, load path analysis, and tolerance stack-up evaluation to ensure consistent alignment across the full workspace. The completed gantry was integrated with the lab's existing data acquisition and imaging systems, enabling controlled parametric studies of eel-inspired undulatory locomotion — contributing to ongoing research on biological propulsion mechanisms and their application to underwater robotic systems.