SUT · GA-Optimized PID Control of SCARA Robot
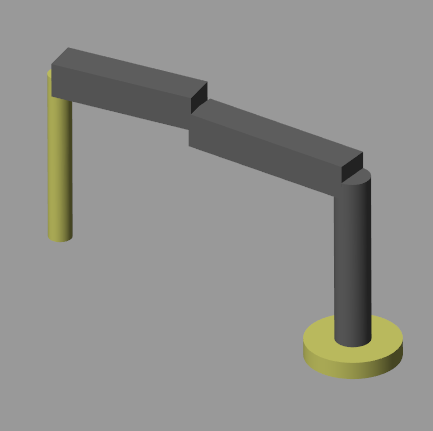
Designed and optimized PID controllers for each joint motor of a SCARA (RRP) robot using multi-objective evolutionary optimization, developed as a course project in Optimal Design at Sharif University of Technology. The control objective was simultaneous minimization of settling time and overshoot — conflicting objectives that resist classical single-objective tuning — while maintaining physical realizability constraints on the damping ratio.
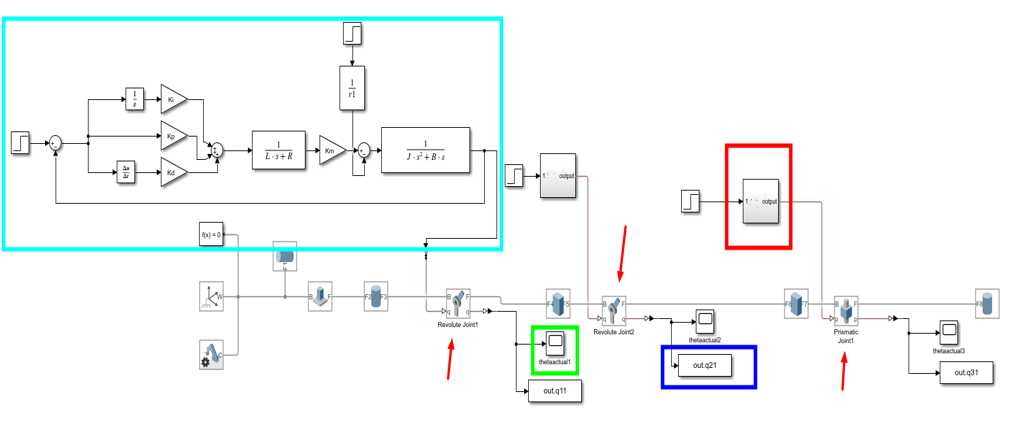
Each joint motor was modeled from first principles: electromechanical equations (R = 100 Ω, Km = Kb = 5.5 Nm/A, Jm = 0.1 kg·m², gearbox ratio r = 25) yield a transfer function with a zero at the origin, capturing back-EMF effects. The full 3-joint system was simulated in MATLAB Simulink with step inputs applied to all joints simultaneously. For the PD case (2nd-order closed-loop), closed-form expressions for ωn and ζ enabled analytic objective formulation: objectives were set as 1/ωn (minimize settling time) and 1−ζ (minimize overshoot), with the constraint ζ ≤ 1. The integral gain Ki (which promotes a 3rd-order system with no closed-form expression) was determined separately by trial and error, yielding Ki = 1 as optimal.
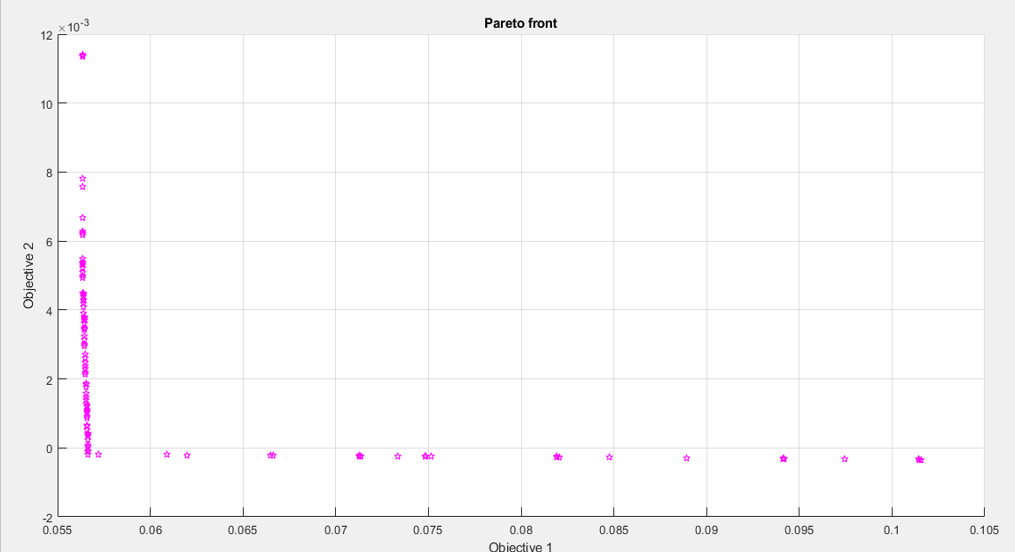
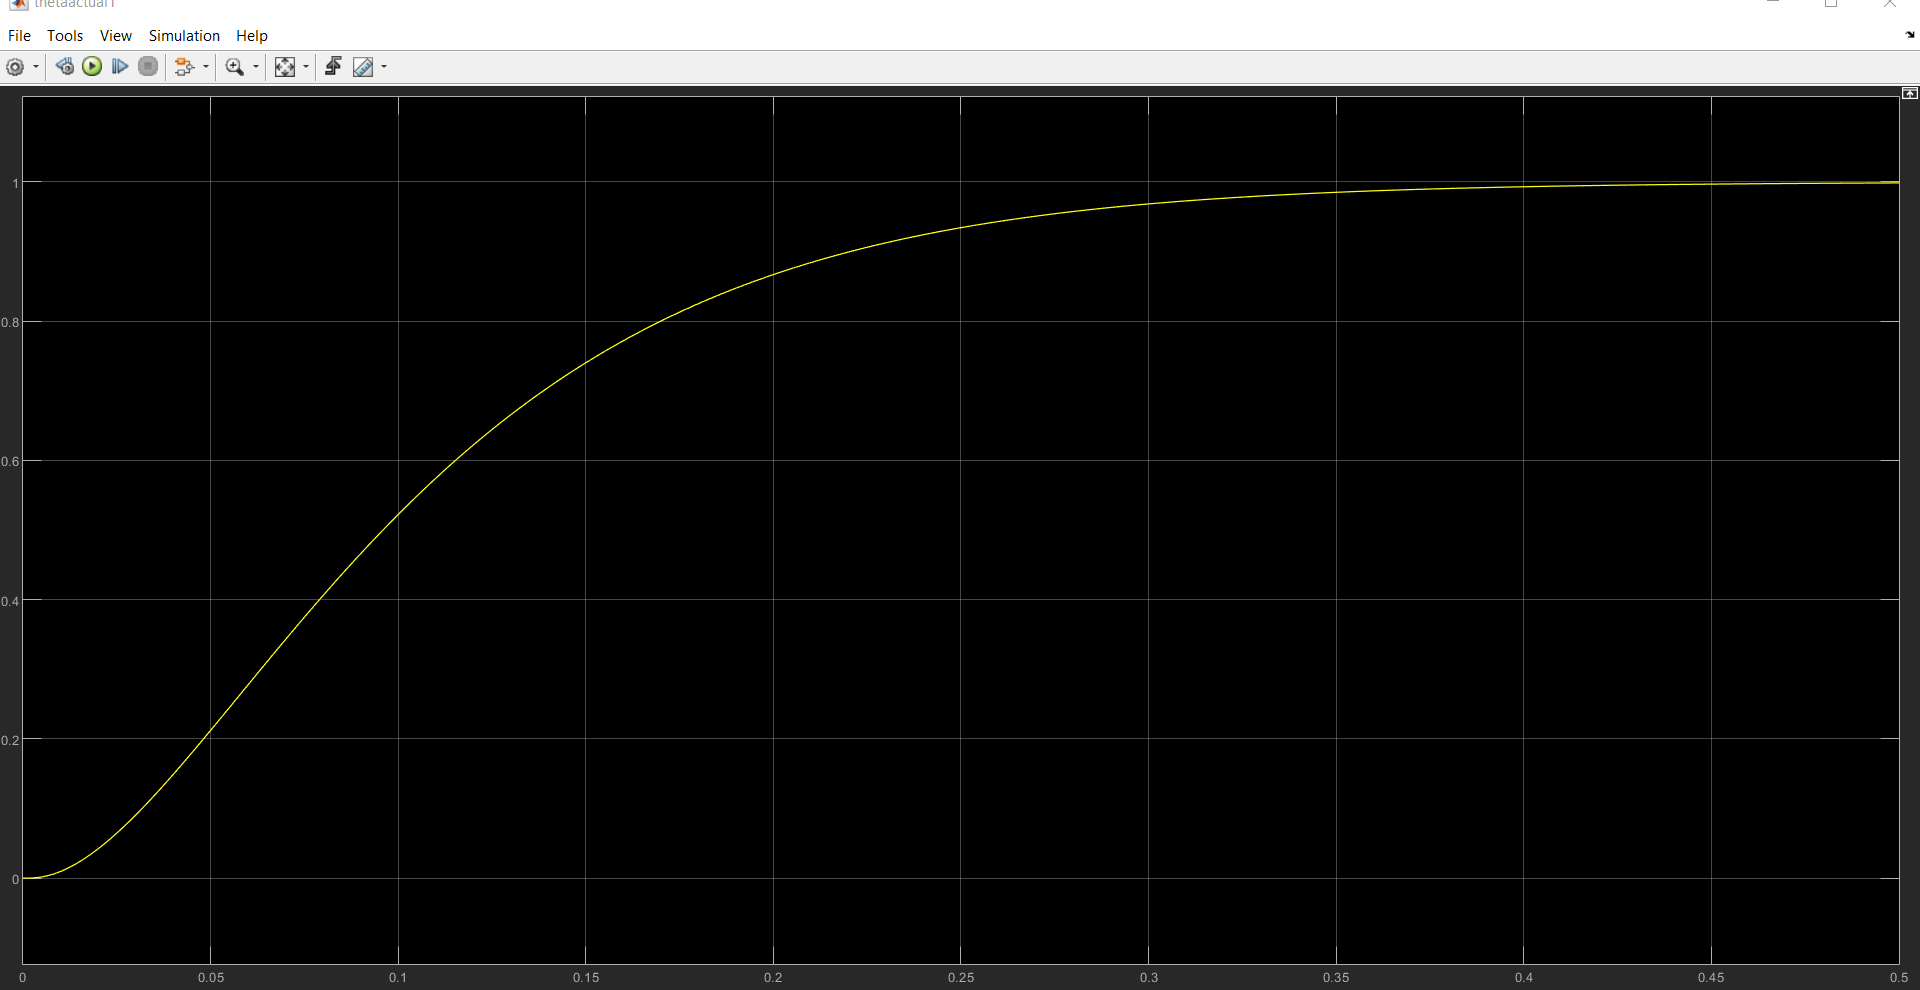
NSGA-II (gamultiobj) was run with population size 200, 2,000 generations, and Pareto front fraction = 1. The optimal solution was selected from the Pareto front by prioritizing minimum 1/ωn, achieving settling time ≈ 0.33 s with zero overshoot across all three joints. Comparison against Ziegler–Nichols and Åström–Hägglund classical tuning methods (via ITD model approximation) demonstrated the GA-optimized controller's decisive advantage: both classical methods stabilized the system but required over 100 seconds to reach steady state.