UCSD · KUKA YouBot Mobile Manipulation
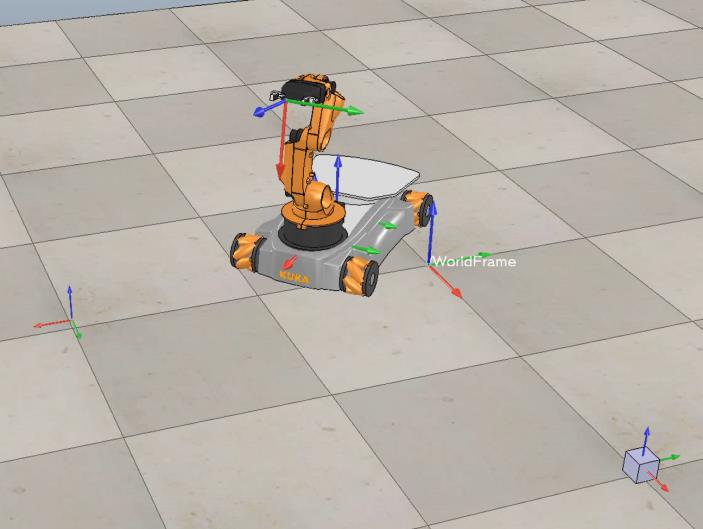
Implemented a complete motion planning and feedback control pipeline for the KUKA YouBot mobile manipulator performing autonomous pick-and-place tasks, developed as a graduate Robotics course project at UC San Diego. The entire system was implemented in MATLAB and validated through simulation in CoppeliaSim, integrating trajectory generation, odometry-based state estimation, and closed-loop end-effector control.
The pipeline comprises three tightly integrated modules: a TrajectoryGenerator that plans smooth end-effector paths between configurations using screw-based interpolation; a NextState odometry module that propagates the mobile base pose using first-order Euler integration of wheel velocities (Chapter 13 kinematics); and a FeedbackControl function implementing a feedforward + PI controller using the robot's 6-DOF body Jacobian to compute joint velocity commands from end-effector pose error. A joint velocity limiter was incorporated to prevent configuration discontinuities near physical limits.
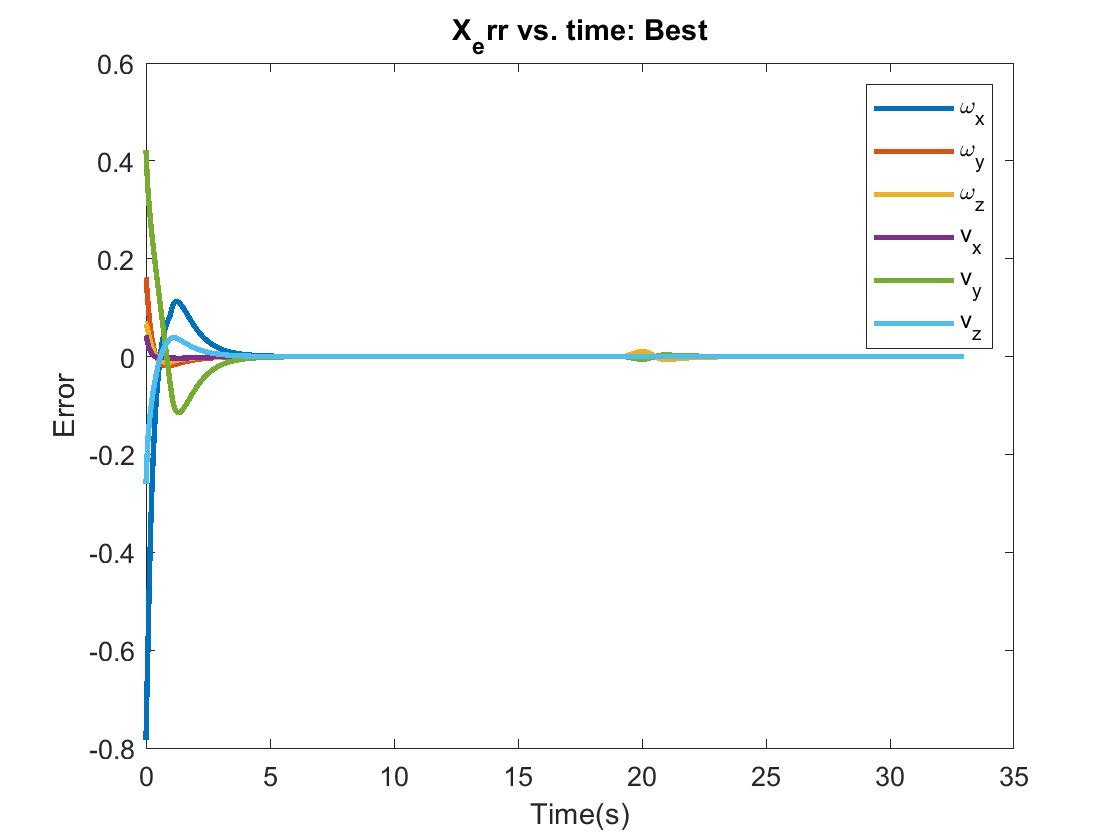
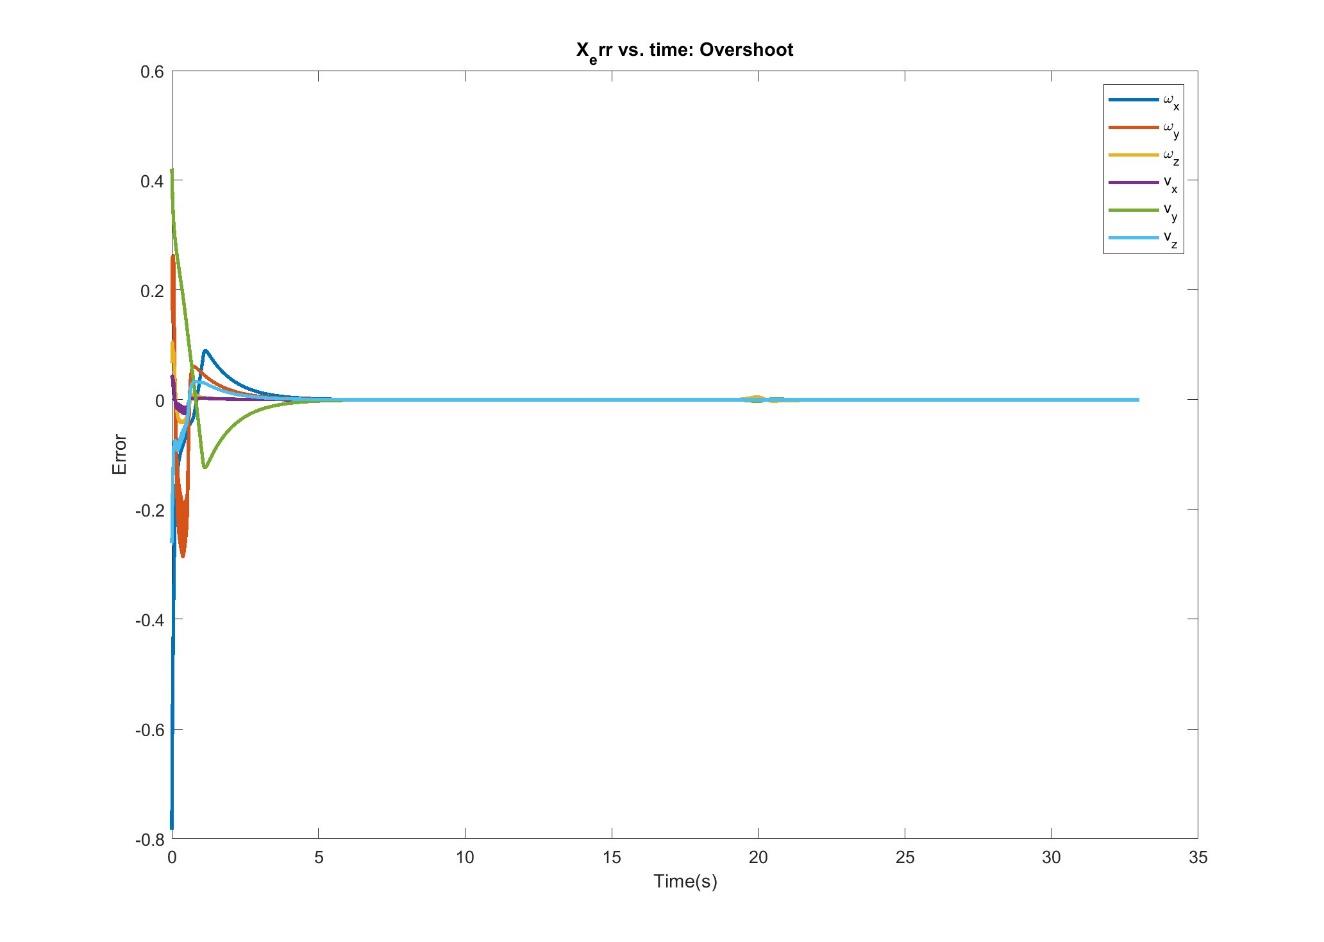
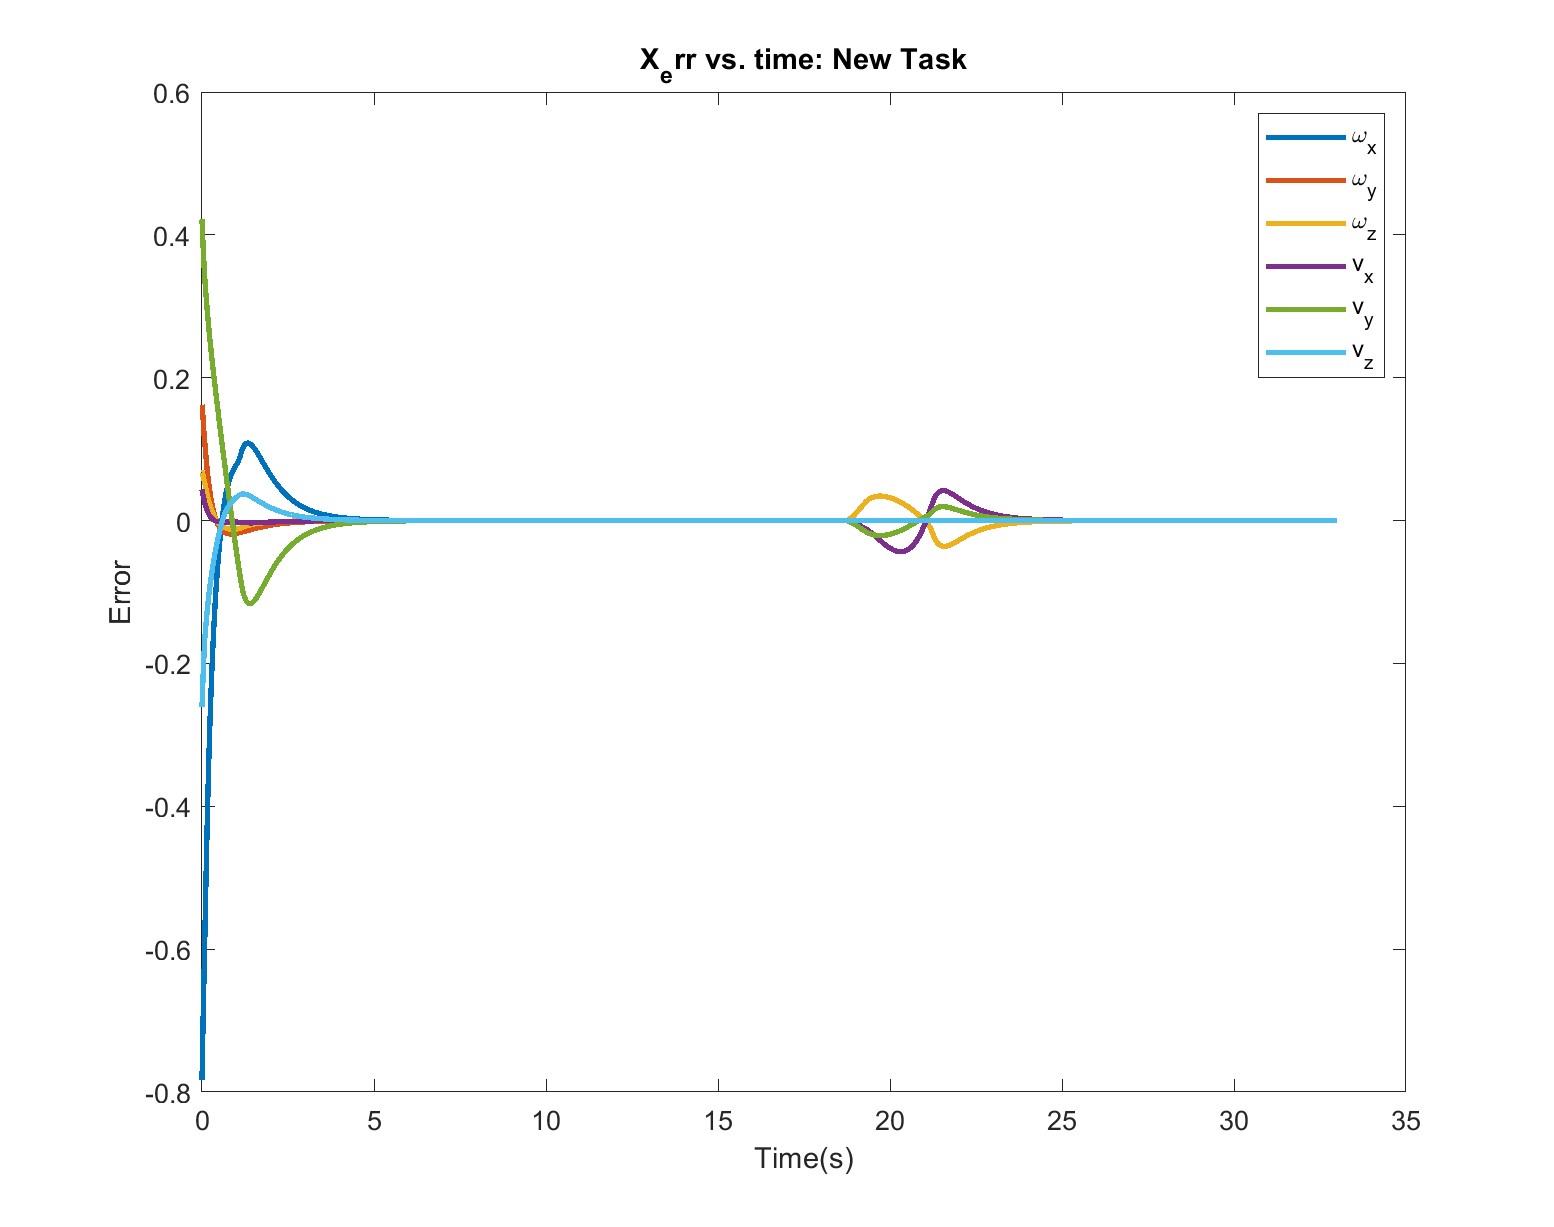
Three test scenarios were evaluated: an Overshoot case (Kp = 0.1, Ki = 20) deliberately demonstrating integral windup behavior for pedagogical analysis; a Best case (Kp = 10, Ki = 5) achieving rapid error convergence within 5 seconds with minimal oscillation; and a New Task case with custom cube configurations (initial: x = 0.6 m, y = 0.6 m; final: x = 0.7 m, y = −0.8 m). All three tasks completed without encountering kinematic singularities. Results confirmed the PI controller's effectiveness in eliminating steady-state error across diverse task configurations.