UCSD · UR3e Robot Laboratory Series
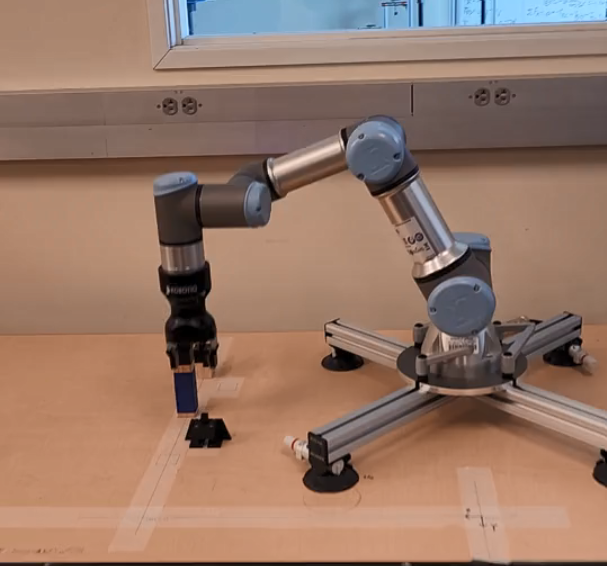
A three-part laboratory series in the MAE 204 Robotics course at UC San Diego (Prof. Michael Tolley, Winter 2024), using the Universal Robots UR3e — a 6-DOF collaborative robot arm with a Robotiq Hand-E gripper — to bridge theoretical robotics with hands-on hardware implementation.
Lab 1 — Robot Programming & Tower of Hanoi: Introduced the UR3e hardware and teach pendant interface. Programmed the robot to solve a Tower of Hanoi task using waypoint-based motion sequences, managing gripper open/close actions (position=0 open, position=100 close) with ~10 mm z-clearance during block release. Standby configuration: [−30, −90, 90, −90, −90, 150]°.
Lab 2 — Forward Kinematics: Implemented forward kinematics using the product-of-exponentials formula. Derived the six screw axes S₁…S₆ and end-effector zero-configuration matrix M from the robot geometry (base at [0, −300, 88] mm), then validated the MATLAB implementation against measured end-effector positions at multiple joint configurations.
Lab 3 — Inverse Kinematics & Assembly: Implemented numerical IK via Newton–Raphson with Moore–Penrose pseudoinverse of the Jacobian. Updated screw axes to include the Robotiq gripper (d = 155 mm) and computed waypoints to assemble a physical "Effigy" from three scattered parts. All joint angles kept within the ±360° UR3e limits.